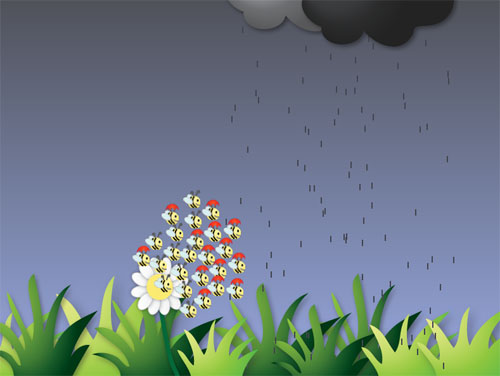
Steering a Swarm of Bees Using Kinect
For the course Programming with Structures we had to simulate a swarm and add interaction using a kinect. The three basic rules of the swarm should be implemented:
- cohesion: members of the swarm fly to the centre of the swarm
- alignment: members of the swarm match their velocity with the average velocity of the swarm
- seperation: members of the swarm don’t overlap, they keep a certain distance to the other members
Next to this the swarm should have an enemy. We made a swarm of bees, normal bees and umbrella bees. The normal bees are afraid of the rain, and avoid the rain. The umbrella bees are not afraid of the rain and can go through it. The person in front of the kinect can change the position of the cloud with rain and in this case influences the behaviour of the swarm. The kinect tracks the contour and maps the position to a position on the screen. Besides this the bees are attracted by the flower.
Tools used
Adobe Illustrator
C++ with openFrameworks
Kinect